HolderModel


HolderModel
表示零阶保持器的单入单出模型.
HolderModel[specs]
表示规范为 specs 的保持器.
更多信息
- HolderModel 亦称为零阶保持 (ZOH),一阶保持 (FOH) 和逆采样.
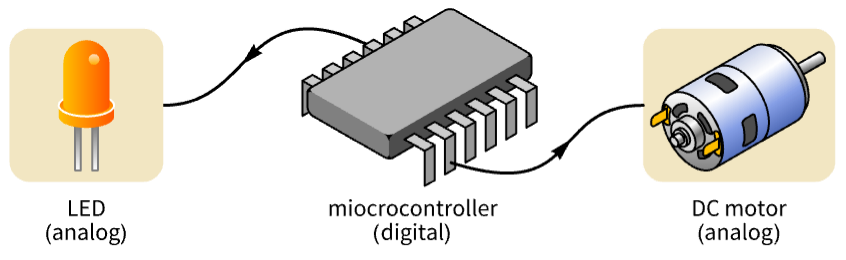
- HolderModel 通常用于将来自数字微控制器或数字信号处理器的离散时间信号转换为在物理世界或物理世界模型中驱动时使用的连续时间信号.
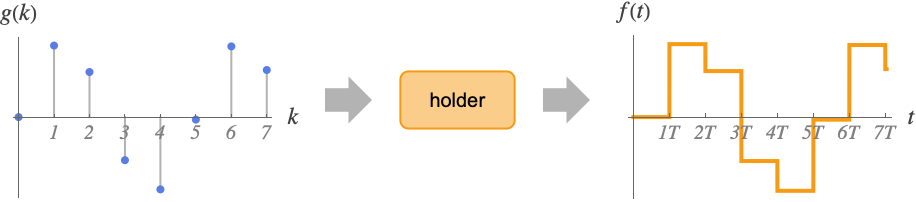
- 保持器是一种运算模型,它接受整数定义的离散时间信号
 ,生成连续时间信号
 ,其中
 是采样周期. 使采样点之间的值保持恒定.
- 规范 spec 是一个关联,可以有以下键:
-
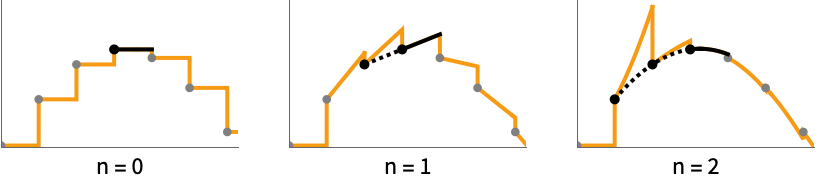
"InputVariables" {u[t]} 输入变量 "Order" 0 保持器的阶数,为非负整数 "OutputVariables" {y[t]} 输出变量 "SamplingPeriod" 1 采样周期 "SignalCount" 1 输入和输出的数量 "TemporalVariable" t 时间变量 - "Order" 属性指定使用的外推的阶数.
 阶外推器使用前面
 个点来导出
 次插值多项式. 然后使用该多项式推断下一个采样周期的值.
- HolderModel[…]["prop"] 可用于获取模型的各种属性.
- "prop" 的值可以是 spec 中的任意键及以下内容:
-
"Properties" 属性名称列表 "PropertyAssociation" 以关联给出的属性名称和值 "PropertyDataset" 以数据集给出的属性名称和值 {p1,p2,…} - 属性 pi
的值
范例
打开所有单元 关闭所有单元基本范例 (2)
HolderModel[]%["PropertyDataset"]r = InputOutputResponse[HolderModel[], Table[Sin[t], {t, 0, 3π}]]Show[Plot[r, {, 0, 3π}], ListPlot[Table[{t, Sin[t]}, {t, 0, 3π}], IconizedObject[«opts»]]]范围 (9)
HolderModel[]HolderModel[<|"Order" -> 1|>]HolderModel[<|"InputVariables" -> u[t], "OutputVariables" -> y[t], "TemporalVariable" -> t|>]%["Dataset"]HolderModel[Association["DiscreteVariables" -> {Subscript[, 1][t]}, "InputVariables" -> {u[t]},
"OutputVariables" -> {y[t]}, "InitialStateValues" -> {}, "TemporalVariable" -> t,
"WhenEvent" -> Mod[t, 1] == 0, "WhenEventAction" -> {Subscript[ ... tion", "StateEquations",
"OutputExpressions", "SignalCount", "Type", "PropertyFunction", "Order", "SamplingPeriod",
"SummaryItems"}], {"InputVariables", "Order", "OutputVariables", "SamplingPeriod",
"SignalCount", "TemporalVariable"}]["Properties"]HolderModel[Association["DiscreteVariables" -> {Subscript[, 1][t]}, "InputVariables" -> {u[t]},
"OutputVariables" -> {y[t]}, "InitialStateValues" -> {}, "TemporalVariable" -> t,
"WhenEvent" -> Mod[t, 1] == 0, "WhenEventAction" -> {Subscript[ ... tion", "StateEquations",
"OutputExpressions", "SignalCount", "Type", "PropertyFunction", "Order", "SamplingPeriod",
"SummaryItems"}], {"InputVariables", "Order", "OutputVariables", "SamplingPeriod",
"SignalCount", "TemporalVariable"}]["SamplingPeriod"]HolderModel[Association["DiscreteVariables" -> {Subscript[, 1][t]}, "InputVariables" -> {u[t]},
"OutputVariables" -> {y[t]}, "InitialStateValues" -> {}, "TemporalVariable" -> t,
"WhenEvent" -> Mod[t, 1] == 0, "WhenEventAction" -> {Subscript[ ... tion", "StateEquations",
"OutputExpressions", "SignalCount", "Type", "PropertyFunction", "Order", "SamplingPeriod",
"SummaryItems"}], {"InputVariables", "Order", "OutputVariables", "SamplingPeriod",
"SignalCount", "TemporalVariable"}][{"Order", "SignalCount"}]HolderModel[Association["DiscreteVariables" -> {Subscript[, 1][t]}, "InputVariables" -> {u[t]},
"OutputVariables" -> {y[t]}, "InitialStateValues" -> {}, "TemporalVariable" -> t,
"WhenEvent" -> Mod[t, 1] == 0, "WhenEventAction" -> {Subscript[ ... tion", "StateEquations",
"OutputExpressions", "SignalCount", "Type", "PropertyFunction", "Order", "SamplingPeriod",
"SummaryItems"}], {"InputVariables", "Order", "OutputVariables", "SamplingPeriod",
"SignalCount", "TemporalVariable"}]["PropertyAssociation"]HolderModel[Association["DiscreteVariables" -> {Subscript[, 1][t]}, "InputVariables" -> {u[t]},
"OutputVariables" -> {y[t]}, "InitialStateValues" -> {}, "TemporalVariable" -> t,
"WhenEvent" -> Mod[t, 1] == 0, "WhenEventAction" -> {Subscript[ ... tion", "StateEquations",
"OutputExpressions", "SignalCount", "Type", "PropertyFunction", "Order", "SamplingPeriod",
"SummaryItems"}], {"InputVariables", "Order", "OutputVariables", "SamplingPeriod",
"SignalCount", "TemporalVariable"}]["PropertyDataset"]Short[r1 = InputOutputResponse[HolderModel[<|"Order" -> 1|>], Table[Sin[t], {t, 0, 2.5π}]]]Show[Plot[r1, {, 0, 2.5π}, PlotRange -> All], ListPlot[Table[{t, Sin[t]}, {t, 0, 2.5π}], IconizedObject[«opts»]]]Short[r2 = InputOutputResponse[HolderModel[<|"Order" -> 1, "SamplingPeriod" -> 0.5|>], Table[Sin[t], {t, 0, 2.5π, 0.5}]]]Show[Plot[r2, {, 0, 2.5π}, PlotRange -> All], ListPlot[Table[{t, Sin[t]}, {t, 0, 2.5π, 0.5}], IconizedObject[«opts»]]]NIntegrate[Abs /@ {Sin[] - r1[[1]], Sin[] - r2[[1]]}, {, 0, 2.5π}]应用 (1)
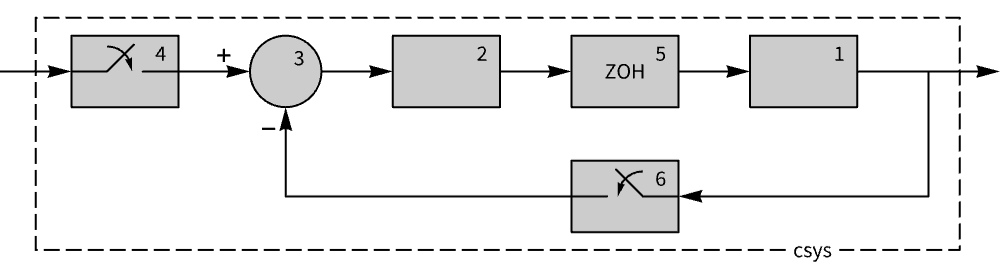
csys = SystemsConnectionsModel[{TransferFunctionModel[{{{1.}}, (1 + s)^3}, s],
TransferFunctionModel[{{{4.539074548064891 - 9.145098981931369* + 4.606282997931085*^2}},
{{0.23358983848622455 - 0.5071796769724491* + 0.2735898384862246*^2}}}, , ... ummaryItems"}], {"InputVariables", "OutputVariables", "SamplingPeriod", "SignalCount",
"TemporalVariable"}]}, {{4, 1} -> {3, 1}, {3, 1} -> {2, 1}, {2, 1} -> {5, 1}, {5, 1} -> {1, 1},
{1, 1} -> {6, 1}, {6, 1} -> {3, 2}}, {{4, 1}}, {{1, 1}}];r = InputOutputResponse[csys, 1, {t, 0, 10}]Plot[r, {t, 0, 10}]属性和关系 (3)
u = Tanh[t];
sp = 0.5;
基于 WhenEvent 的响应:
r1 = NDSolveValue[{WhenEvent@@{Mod[t, sp] == 0, y[t] -> u}, y[0] == 0, Derivative[1][$][t] == 0, $[0] == 0}, y[t], {t, 0, 5}, DiscreteVariables -> {y[t]}]r2 = InputOutputResponse[SamplerModel[<|"SamplingPeriod" -> sp|>], u, {t, 0, 5}]Plot[{r1, r2}, {t, 0, 5}, PlotRange -> All]u = Tanh[t];
sp = 0.5;


action = {Subscript[x, 1][t], Subscript[x, 2][t], 𝒯[t]} -> {u, Subscript[x, 1][t], 𝒯[t] + sp};


we = WhenEvent@@{Mod[t, sp] == 0, action}

sol = Solve[{Subscript[x, 1][t] == m 𝒯[t] + c, Subscript[x, 2][t] == m(𝒯[t] - sp) + c}, {m, c}]out = m t + c /. sol//Simplifyr1 = NDSolveValue[{we, Derivative[1][$][t] == 0, $[0] == 0, Subscript[x, 1][0] == 0, Subscript[x, 2][0] == 0, 𝒯[0] == 0}, out, {t, 0, 5}, DiscreteVariables -> {Subscript[x, 1][t], Subscript[x, 2][t], 𝒯[t]}]r2 = InputOutputResponse[HolderModel[<|"SamplingPeriod" -> sp, "Order" -> 1|>], u, {t, 0, 5}]Plot[{r1, r2}, {t, 0, 5}, PlotRange -> All]f = 3;
u = Sech[f t];
sp = 1 / ( 50f);sys = SystemsConnectionsModel[{SamplerModel[<|"SamplingPeriod" -> sp|>], HolderModel[<|"SamplingPeriod" -> sp|>]}, {{1, 1} -> {2, 1}}, {{1, 1}}, {{2, 1}}]InputOutputResponse[sys, u, {t, 0, π}];
Plot[{u, %[[1]]}, {t, 0, π}, PlotRange -> All]
Wolfram Research (2024),HolderModel,Wolfram 语言函数,https://reference.wolfram.com/language/ref/HolderModel.html.
文本
Wolfram Research (2024),HolderModel,Wolfram 语言函数,https://reference.wolfram.com/language/ref/HolderModel.html.
CMS
Wolfram 语言. 2024. "HolderModel." Wolfram 语言与系统参考资料中心. Wolfram Research. https://reference.wolfram.com/language/ref/HolderModel.html.
APA
Wolfram 语言. (2024). HolderModel. Wolfram 语言与系统参考资料中心. 追溯自 https://reference.wolfram.com/language/ref/HolderModel.html 年